Hybrid humanoid finger grasps tofu and pinches 0.1 mm paper in lab tests
What was demonstrated
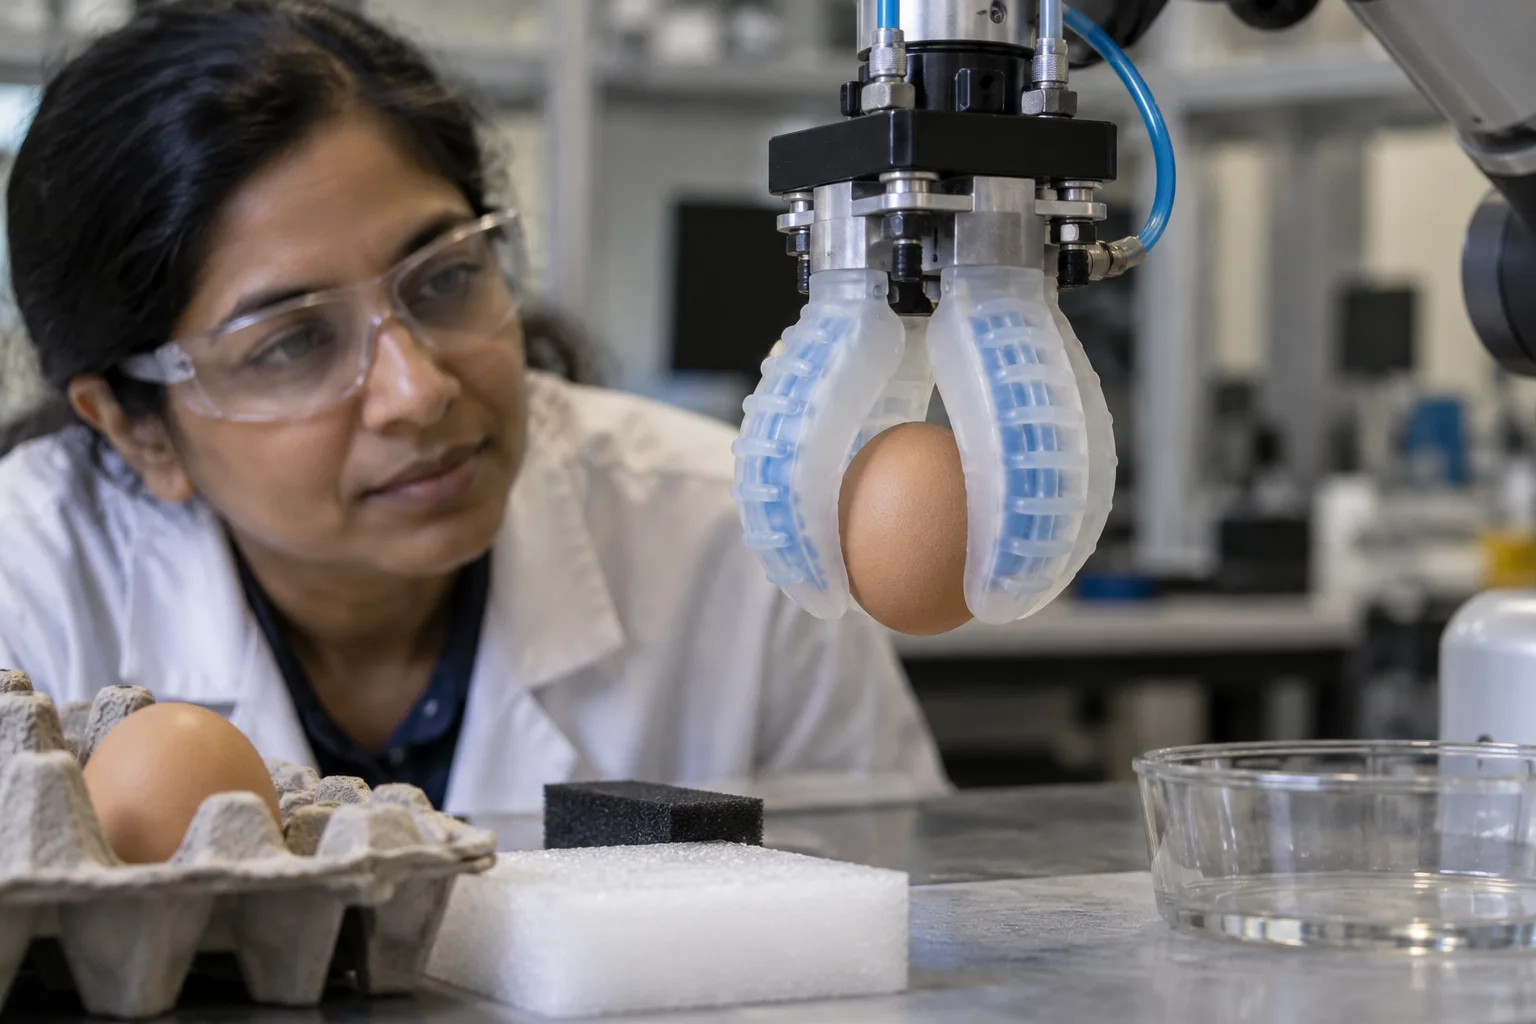
In laboratory experiments reported in the abstract, grippers built from a humanoid finger grasped tofu, pinched 0.1 mm paper, held a 23.2 cm basketball and supported 5.275 kg weights. The finger has rigid bones, flexible springs and a soft silicone skin, and a pneumatic actuator sits between the bones and the skin. The sources checked report no success rates, trial counts or grip force figures.
Why it matters
The authors present a hybrid finger, with rigid bones, flexible springs and soft skin, as a design that can handle both small, fragile items and heavier loads. The reported tests are the authors' own laboratory demonstrations, and the sources checked do not show consistent performance across a range of delicate objects.
Caveats
- The tests are the authors' own laboratory demonstrations. The sources checked report no success rates, trial counts or grip forces, so reliability is not established.
- The finger keeps rigid bones, so it is a hybrid design rather than a fully soft gripper.
- The sources checked do not describe performance with other delicate foods, or in wet, cluttered or real-world settings.
Technology profiles
Sources
- peer reviewed paper
Humanoid finger with rigid-flexible-soft structure
Boyang Lyu, Huai Xiao, Qingxin Meng et al.. Nature Communications, 12 Nov 2025. DOI: 10.1038/s41467-025-65367-x.
Last reviewed 21 Oct 2026.